Specifications
| Payload | 10 kg |
|---|---|
| Max. load | 15 kg |
| Stroke | 150 mm |
| Gripping width | 4-152 mm |
| Grip force | 10-240 N |
| Repeatability | 0.1 mm |
| Weight | 1.15 kg |
| IP rating | IP67 |
| Voltage | 20-25 V DC |
Description
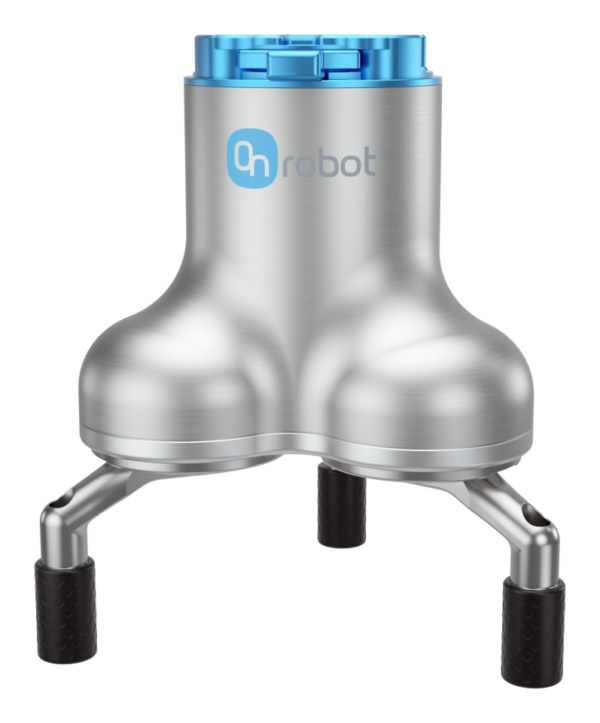
The OnRobot 3FG15 is an electric three-finger gripper for round and cylindrical workpieces. Three synchronized fingers centre the part as they close, which gives stable three-point contact and accurate positioning when loading machine chucks.
It can grip externally or internally. Depending on finger position and fingertips, external grip diameters range from 4 to 152 mm and internal diameters from 35 to 176 mm, with a maximum stroke of 150 mm. Payload is up to 10 kg force-fit with the normal grip (8 kg with the flexible grip) and 15 kg form-fit. The normal grip gives 10 to 240 N and is used when the diameter is known; the flexible grip, up to 140 N, handles parts of unknown or varying diameter. A brake holds the workpiece without power consumption, also if power is lost.
The gripper weighs 1.15 kg, is rated IP67 and runs on 20 to 25 V DC. Fingers and fingertips (steel, silicone, optional knurled or X-shaped) can be changed or customized.
Typical applications
- CNC lathe machine tending with cylindrical workpieces
- Material handling of round parts with internal or external gripping
- Assembly and insertion of cylindrical components
Compatible with
- ABB
- Denso
- DOBOT
- Doosan
- Epson
- FANUC (CRX, CR and LR Mate series)
- Hanwha
- JAKA
- Kassow
- Kawasaki
- KUKA
- NACHi
- Omron TM
- Techman
- Standard Bots
- Universal Robots
- Yaskawa
Downloads
Related products
-
OnRobot
OnRobot 2FG7
- Payload
- 7 kg
- Grip force
- 20-140 N
- Repeatability
- +/-0.1 mm
€4,078.00 excl. VAT€4,934.38 incl. VAT -
OnRobot
OnRobot 2FGP20
- Payload
- 20 kg
- Grip force
- 80-400 N
- Repeatability
- +/-0.5 mm
€10,759.00 excl. VAT€13,018.39 incl. VAT -
OnRobot
OnRobot 2FG14
- Payload
- 14 kg
- Grip force
- 40-280 N
- Repeatability
- +/-0.1 mm
€5,106.00 excl. VAT€6,178.26 incl. VAT -
OnRobot
OnRobot 3FG25
- Payload
- 15 kg
- Grip force
- 50-450 N
- Repeatability
- 0.1 mm
€6,003.00 excl. VAT€7,263.63 incl. VAT