Specifications
| Payload | 1 kg |
|---|---|
| IP rating | IP42 |
| Weight | 0.267 kg |
| Preload force | 3-11 (min 3, medium 7, max 11) N |
| Pad size (per OnRobot spare pad kit) | 35 mm |
| Detachment time (depends on robot speed) | 100-1000 ms |
| Operating temperature | 0-50 degrees C |
Description
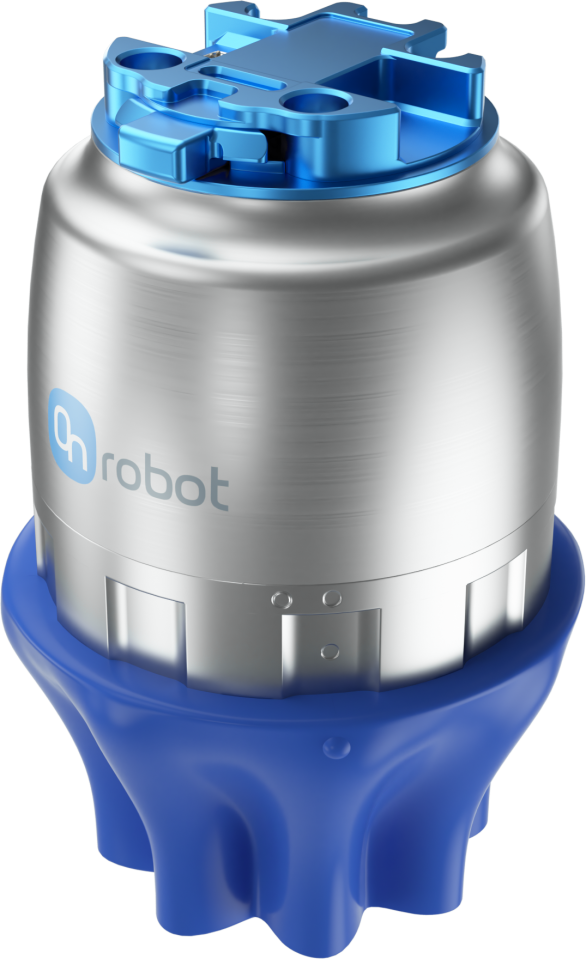
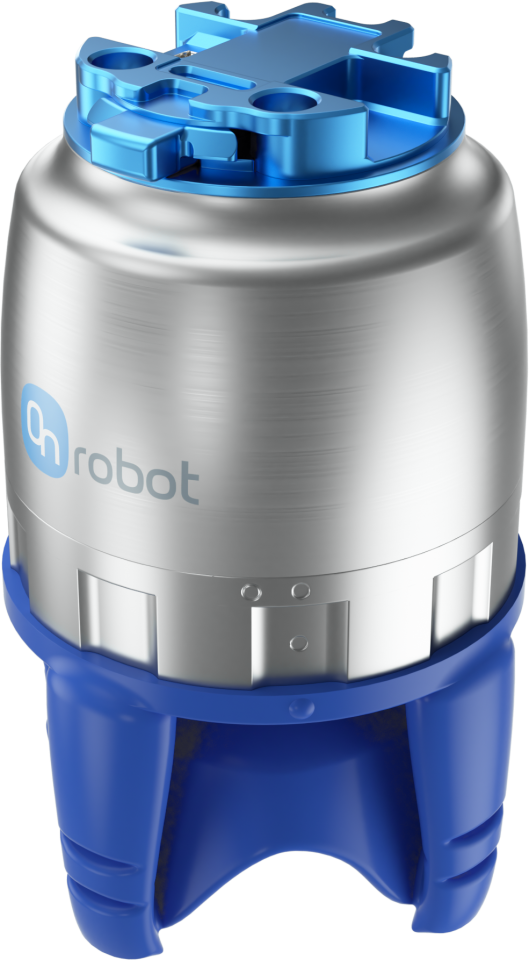
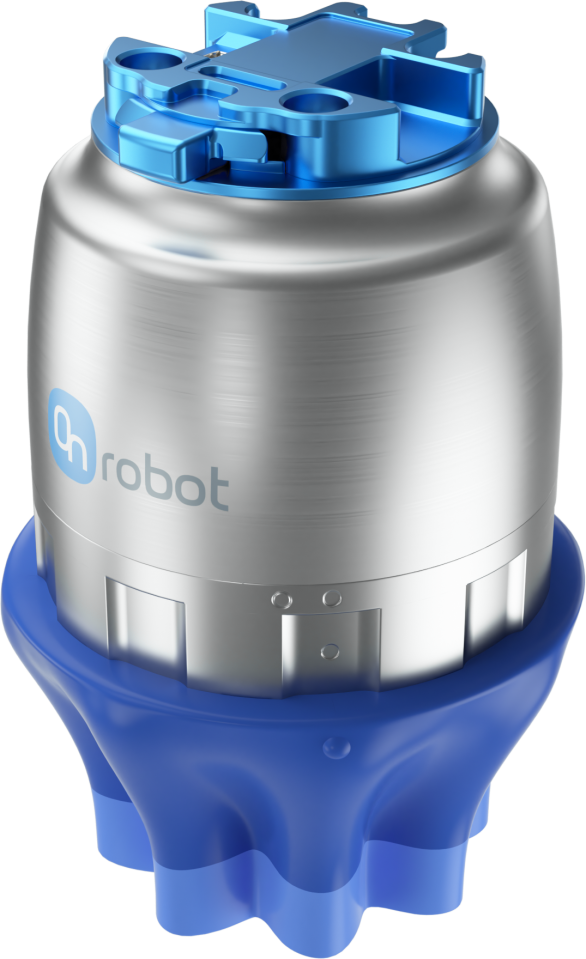
The OnRobot Gecko Gripper SP1 is a passive adhesive gripper that lifts flat, smooth, shiny and perforated workpieces with dry adhesive pads. The pads use van der Waals forces, so the gripper needs no electricity, no compressed air and no control cabling, and it leaves no marks on suitable surfaces. This listing is the SP1, with a maximum payload of 1 kg under suitable conditions. The Gecko range comes in three sizes: SP1 (1 kg), SP3 (3 kg) and SP5 (5 kg); they differ in pad size and payload.
Actual capacity depends on surface roughness, stiffness, cleanliness, preload and how well the load is centred. The SP1 works with a preload of 3 to 11 N. The gripper works best on flat, stiff, smooth, clean and dry surfaces; dust, grease, oil and water prevent adhesion, and soft or rough materials may not give enough pad contact. The robot program must make controlled contact, apply the preload, lift with the load centred and release by a peel movement or a fixture. Check the robot’s collision detection settings, because contact can trip it. The pads wear out over time (change-out interval around 200,000 cycles) and can be cleaned with isopropyl alcohol and a lint-free cloth. The gripper holds the part on power loss and is rated IP42.
Typical applications
- Handling glass, polished metal and glossy surfaces without marks
- Printed circuit boards, aluminium mesh and head gaskets
- Pick and place of flat, stiff parts where vacuum is unsuitable
Compatible with
- ABB
- Denso (not Cobotta Pro)
- DOBOT
- Doosan (not CS-11P/CS-12P versions)
- Epson
- FANUC
- Hanwha
- JAKA
- Kassow
- Kawasaki
- KUKA
- NACHi
- Omron TM
- Standard Bots
- Techman
- Universal Robots
- Yaskawa
Downloads
Related products
-
OnRobot
OnRobot MG10
- Payload
- 10 (pure steel, no pads, parallel to the ground, 3G) kg
- Grip force
- 300 N
- IP rating
- IP67
€2,607.00 excl. VAT€3,154.47 incl. VAT -
OnRobot
OnRobot Soft Gripper tool SG-a-H
- Payload
- 2.2 kg
- Gripping width
- 11-75 mm
- Weight
- 0.168 kg
€1,005.00 excl. VAT€1,216.05 incl. VAT -
OnRobot
OnRobot Soft Gripper tool SG-b-H
- Payload
- 1.1 kg
- Gripping width
- 24-118 mm
- Weight
- 0.172 kg
€1,005.00 excl. VAT€1,216.05 incl. VAT -
OnRobot
OnRobot Soft Gripper tool SG-a-S
- Payload
- 1.5 kg
- Gripping width
- 11-75 mm
- Weight
- 0.168 kg
€1,005.00 excl. VAT€1,216.05 incl. VAT